

BiGym 2.0#
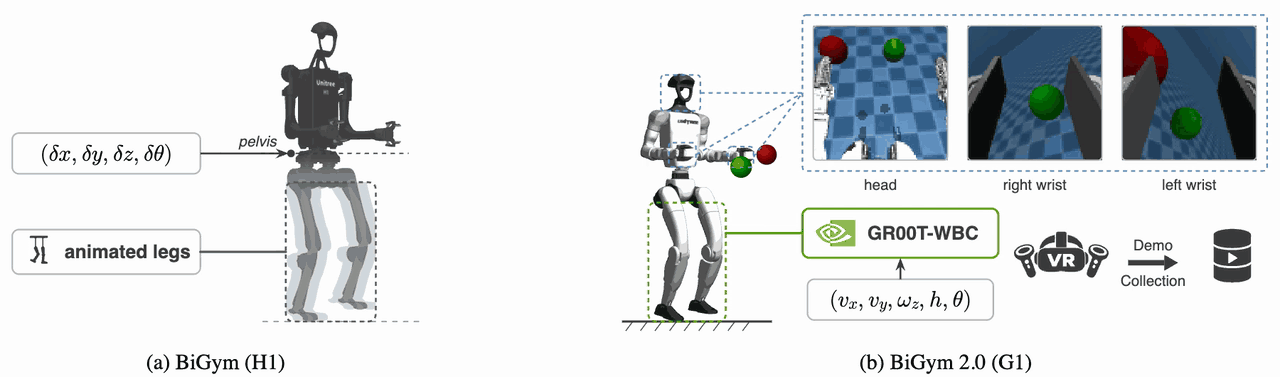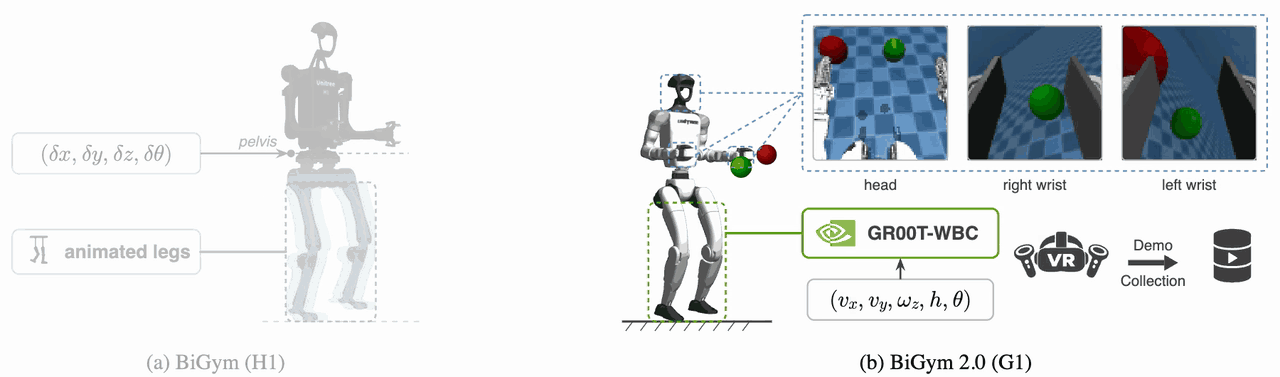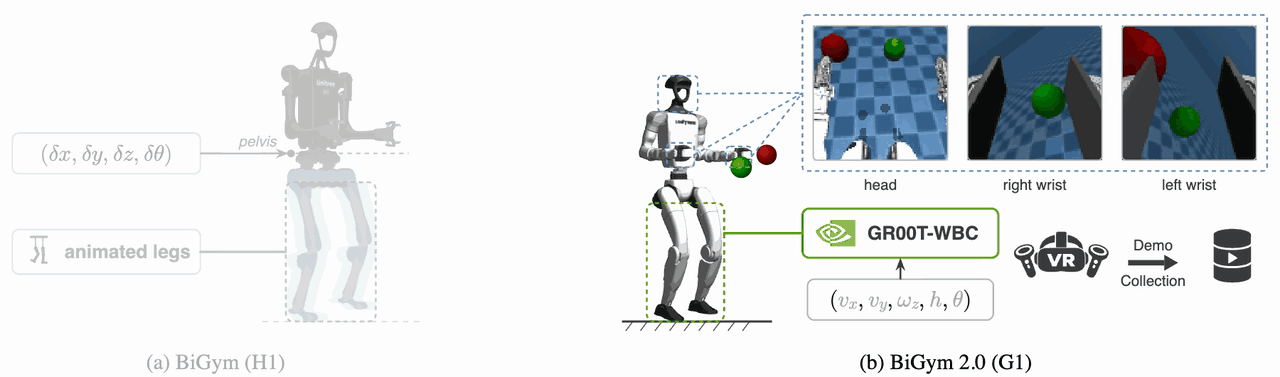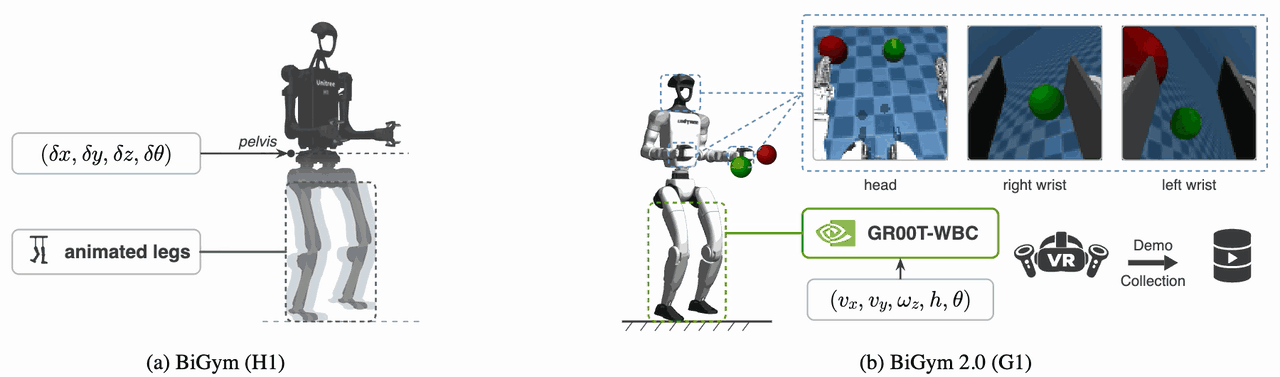
BiGym 2.0 is a benchmark for whole-body humanoid manipulation. A Unitree G1 with two-finger grippers performs 20 household tasks in MuJoCo. A frozen lower-body controller, NVIDIA’s GR00T-WBC, runs inside every environment step and keeps the robot balanced and walking. Your policy commands the base, the 14 arm joints and the two grippers. Each task has 60 human VR demonstrations. Learned policies and coding agents are scored on the same 100 evaluation seeds.
Build a task, reset it and take one step:
import numpy as np
from bigym.loco import make

env = make("move_plate")                # the task's official configuration
timestep = env.reset(seed=620000)       # the first evaluation seed
action = np.zeros(env.action_spec().shape, dtype=np.float32)
timestep = env.step(action)             # one 50 Hz control step
print(timestep.rgb_obs.shape)           # (3, 3, 84, 84)
print(timestep.low_dim_obs.shape)       # (50,)
Start here
The benchmark
License and citation#
The code is released under the Apache 2.0 License. The GR00T-WBC weights are NVIDIA’s, under the NVIDIA Open Model License.
Cite BiGym 2.0 with the BibTeX entry on the Research page.