

Tasks#
The task registry bigym.loco.tasks.TASKS holds 40 tasks, the G1 versions of
the BiGym tasks. 20 of them form the benchmark. Each has 60 human VR
demonstrations and an episode budget derived from them. The other 20 are
listed under Tasks released later. Scenes, resets and
tolerances are adapted to the Unitree G1 with Dex1-1 grippers, so scores are
not comparable with BiGym tasks of the same name.
from bigym.loco import make
env = make("move_plate")   # official configuration for this task
TASKS[name].episode_length is the budget in env steps. See
Episode budgets.
Scene group |
Tasks |
Action |
|---|---|---|
Reaching |
|
20 |
Table-top |
|
20 |
|
21 |
|
Dishwasher |
|
21 |
Kitchen counter |
|
20 |
|
21 |
Action is the action dimension. The 21-dim tasks add a torso-pitch command in
slot 4, and their low-dim observation has 56 entries instead of 50 because it
includes the waist joints. The demonstrations use the same layout.
Action layout lists the slots, and
env.wholebody_action_layout() reports them.
Reward and termination#
Reward is sparse: 1.0 once the success condition has held for 1.0 s (50 control steps), 0 otherwise. An episode ends on the first of:
success,
task failure: the pelvis is more than 10 m from the origin, or the task’s fail-fast condition is met,
physics instability,
the episode budget.
A fall does not end the episode. It labels the episode fell, which never
counts as a success. Success and falls
defines a fall.
Terms used below:
Held: a gripper pad touches the object. Most success conditions require every object to be released.
Fail-fast: a condition that ends the episode early with no reward. Tasks without one let the robot pick up a dropped object again.
Settled pelvis: the pelvis position after the 200 warmup steps that
resetruns before the policy takes over.Doors, drawers and dishwasher trays report a normalised position from 0 (closed) to 1 (open). A tolerance of 0.1 is 9° on a 90° door and 0.038 m on a 0.38 m drawer. The dishwasher trays travel 0.50 m (bottom) and 0.45 m (middle).
Reaching#
Code: bigym/envs/reach_target.py
Touch a coloured sphere of radius 0.05 m with the hand. No objects are involved.
Success: the pinch centre between the gripper pads is within 0.05 m of the target centre, so it must be inside the ball.
Reset: each target moves ±0.05 m in x, ±0.10 m in y and ±0.10 m in z around its base position, 0.45 m ahead and 0.8 m up. The robot spawns at the origin.
vs. BiGym: targets sit 0.2 m lower and 0.05 m closer. BiGym’s 1.0 m is at the G1’s shoulder line. BiGym counts 0.1 m as reached, which passes on a fingertip graze.
reach_target_single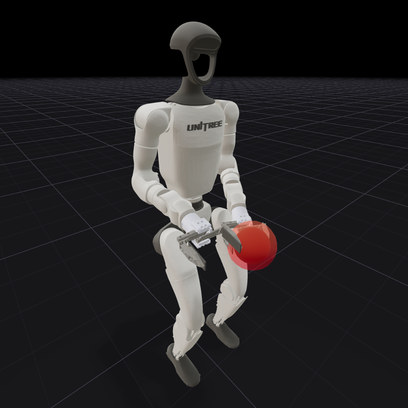
reach_target_multi_modal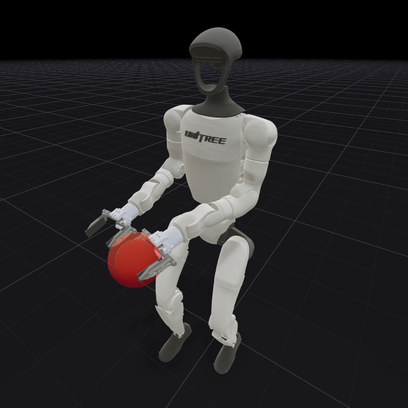
reach_target_dual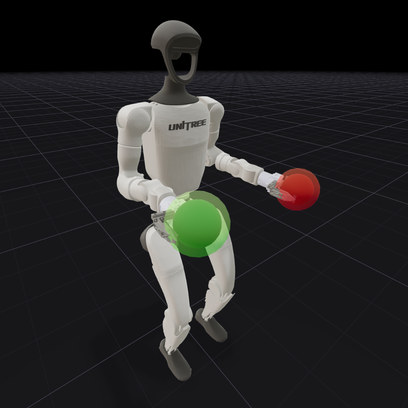
reach_target_single#
One target in the centre. Only the left hand counts.
reach_target_multi_modal#
One target in the centre. Either hand counts.
reach_target_dual#
Two targets 0.2 m left and right of centre, each jittered independently. The left hand must reach the left target and the right hand the right one, at the same time.
Table-top#
Code: bigym/envs/move_plates.py,
bigym/envs/manipulation.py
move_plate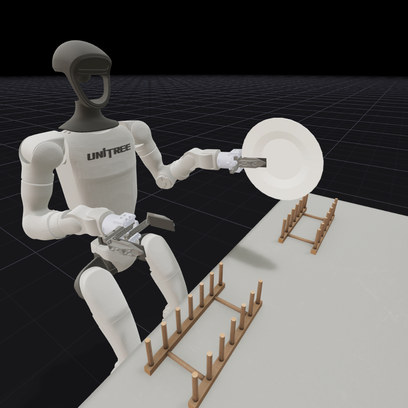
move_two_plates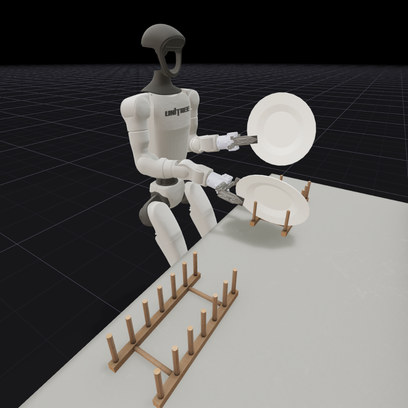
flip_cup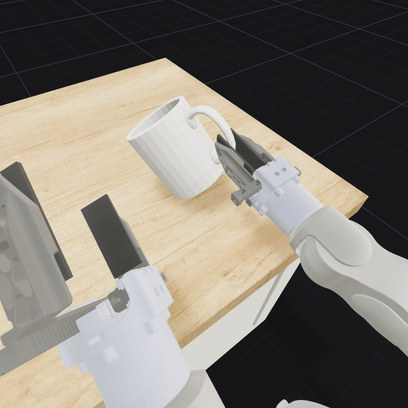
flip_cutlery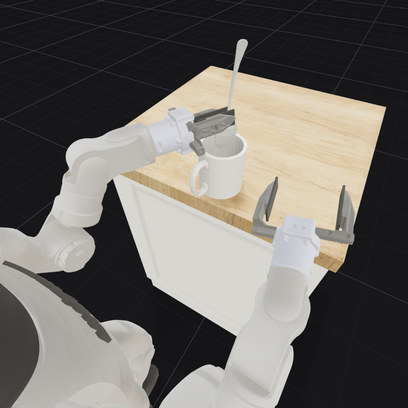
stack_blocks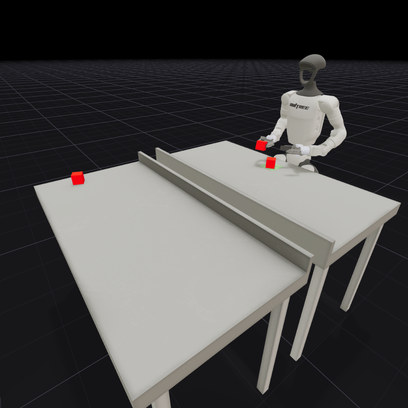
move_plate#
Goal: move the plate from the left draining rack to the right one.
Success: the plate is within 0.05 m of one of the 6 slots of the target rack, stands on edge with its top face toward the robot’s right within 20°, touches the target rack, does not touch the table, and is not held. A plate facing left fails. Fail-fast: the plate touches the floor.
Reset: each rack moves ±0.05 m in x and y. The plate starts in a random slot of the left rack.
vs. BiGym: the table is 0.25 m lower (top at 0.70 m) and the racks are closer, so the slots sit at about 0.85 m instead of 1.10 m.
move_two_plates#
Goal: move both plates from the left draining rack to the right one.
Success: both plates meet the
move_platecondition at once. Same fail-fast.Reset: as
move_plate, with the plates in two different slots.vs. BiGym: same table and racks as
move_plate.
flip_cup#
Goal: turn the upside-down cup upright.
Success: the cup is upright within 5°, touches the counter, and is not held. This is the tightest orientation tolerance in the suite.
Reset: the cup starts upside down in one of 8 spots (a 2 × 4 grid, 0.1 m apart), moved ±0.03 m in x and y, with yaw 180° ± 30°.
flip_cutlery#
Goal: take the spoon out of the mug, turn it over, and put it back.
Success: the spoon points down within 50°, touches the mug, and neither the spoon nor the mug is held.
Reset: the mug starts in one of the same 8 spots, moved ±0.03 m, with random yaw. The spoon stands in it pointing up.
vs. BiGym: BiGym only checks that the mug is released, so a spoon still pinched in the mug counts there.
stack_blocks#
Goal: carry three blocks to the far table and stack them on the green pad.
Success: the lowest block touches the pad, each block touches the one below it and sits at least 0.03 m higher and within 0.05 m horizontally of it, and no block is held. Fail-fast: a block touches the floor.
Reset: the blocks start in 3 of 4 spots in a row 0.15 m apart on the near table, each moved ±0.05 m with random yaw. The pad sits on the far table, moved ±0.04 m in x and ±0.08 m in y, always 0.10 to 0.18 m inside its edge. The robot has to walk across.
vs. BiGym: both tables are 0.25 m lower (tops at 0.70 m). BiGym also accepts a horizontal chain of touching blocks.
Dishwasher#
Code: bigym/envs/dishwasher.py,
dishwasher_cups.py,
dishwasher_cutlery.py,
dishwasher_plates.py
The three load tasks keep the BiGym scene and spawn. The dishwasher door is open at the start of every task.
dishwasher_close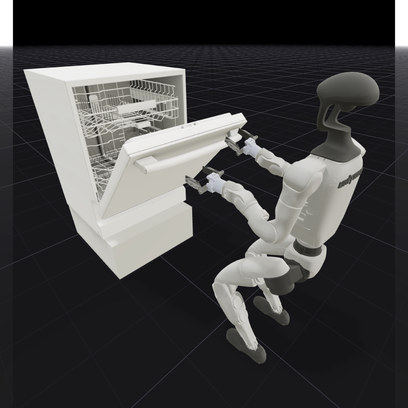
dishwasher_load_cups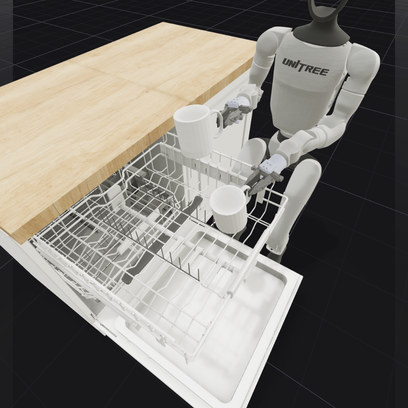
dishwasher_load_cutlery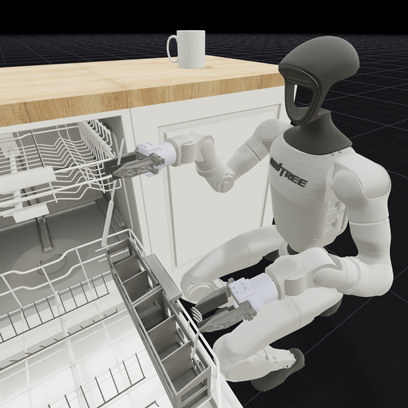
dishwasher_load_plates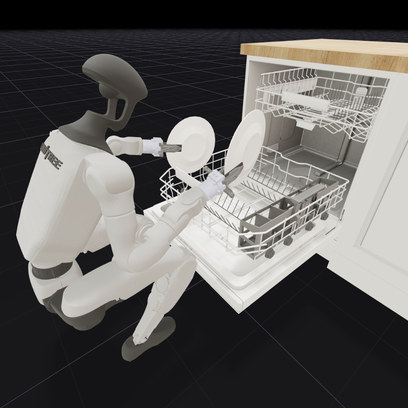
dishwasher_close#
Goal: push both trays in and close the door.
Success: the door is within 4.5° of closed, the bottom tray within 0.025 m and the middle tray within 0.0225 m.
Reset: none. The door is open and both trays are out on every seed.
vs. BiGym: the dishwasher stands on a 0.25 m plinth, so the open door lies at 0.41 to 0.50 m instead of 0.16 to 0.25 m. The G1 cannot reach the lower door, even at its 0.40 m minimum height with the torso pitched.
dishwasher_load_cups#
Goal: put the two cups from the counter into the upper tray.
Success: both cups touch the middle tray and are not held. Any orientation counts. Fail-fast: a cup touches the floor.
Reset: the middle tray is out. The cups start upside down 0.15 m apart, each moved ±0.05 m in x and ±0.02 m in y, with yaw 180° ± 30°. They are 0.65 to 0.75 m from the settled pelvis, one short step.
dishwasher_load_cutlery#
Goal: move the knife and fork from the mug on the counter into the cutlery basket.
Success: both touch the basket and are not held. Fail-fast: an item touches the floor.
Reset: the bottom tray is out. The mug moves ±0.05 m in x and y, with yaw ±90°. The knife and fork stand in it at 90° to each other, ± 5°.
dishwasher_load_plates#
Goal: move the two plates from the drainer into the lower tray.
Success: each plate stands on edge within 20°, facing either way, touches the bottom tray, and is not held. Fail-fast: a plate touches the floor.
Reset: the bottom tray is out. The drainer moves ±0.05 m in x and y. The plates start in 2 of its 3 odd-numbered slots.
Kitchen counter#
Code: bigym/envs/cupboards.py,
bigym/envs/pick_and_place.py
The BiGym wall cabinet is above the G1’s fingertip ceiling of about 1.55 m. Where a task uses it, the G1 scene lowers it 0.32 m and pulls it 0.2 m forward, which puts the bottom shelf at about 1.15 m and the handles at about 1.2 m.
drawer_top_open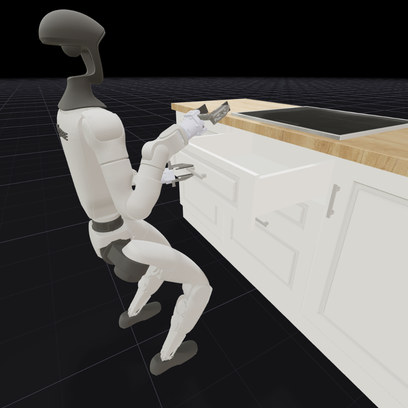
drawer_top_close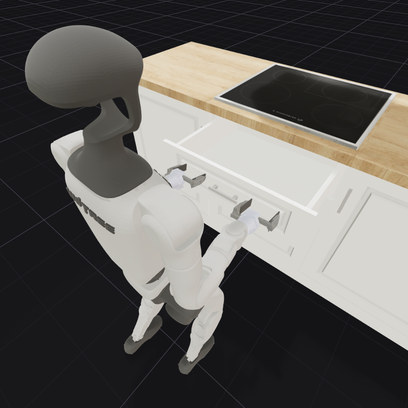
pick_box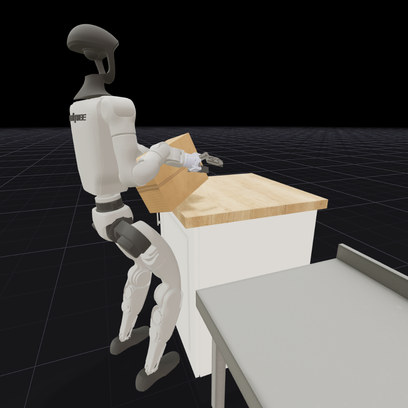
put_cups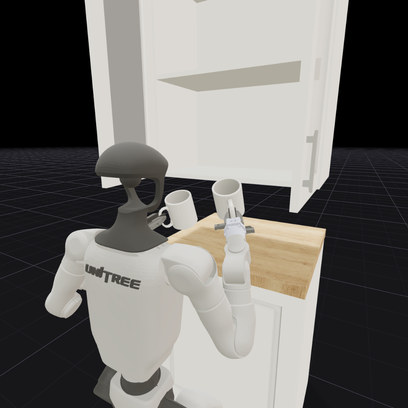
saucepan_to_hob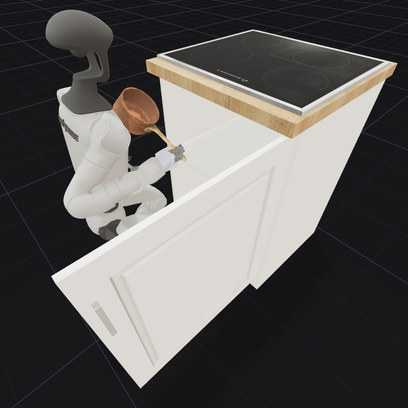
sandwich_remove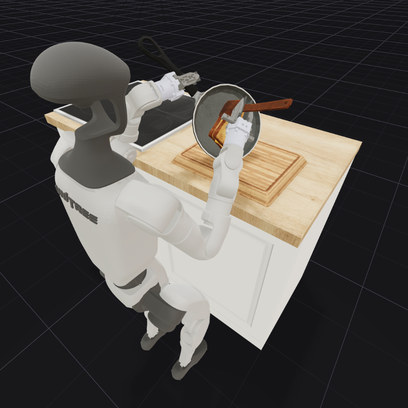
wall_cupboard_open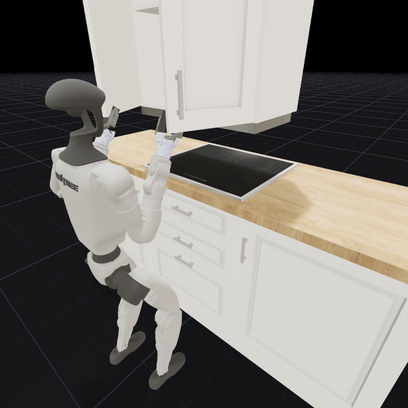
wall_cupboard_close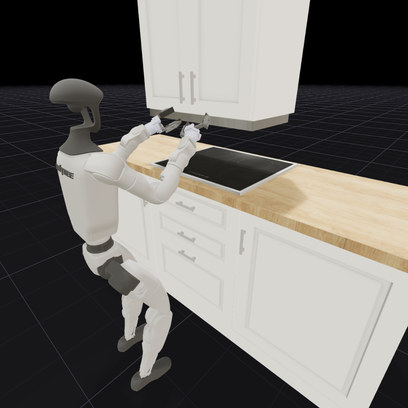
drawer_top_open#
Goal: open the top drawer.
Success: the top drawer is at least 90% open, within 0.038 m of fully out.
Reset: the robot spawns at x 0.12 to 0.14 m, y ±0.05 m, yaw ±5°. The top drawer starts 0 to 15% open and is held there through the warmup.
drawer_top_close#
Goal: close the top drawer.
Success: the top drawer is within 0.038 m of closed.
Reset: the robot pose is drawn as in
drawer_top_open. The top drawer starts 85 to 100% open.
pick_box#
Goal: pick up the box from the side table and put it on the counter.
Success: the box touches the counter, is not held, has its centre over the counter, and has its bottom within 0.03 m of the counter top.
Reset: the box stands upright on a side table 0.7 m ahead and 1 m to the robot’s right, moved ±0.03 m in x and y, with random yaw. The robot has to turn and walk to it.
vs. BiGym: the G1 cannot reach the floor. At its minimum height its hands stay above about 0.4 m with the torso upright and 0.33 m with full pitch. The box therefore starts on a side table with its top at 0.50 m, and the counter is 0.15 m lower (top at 0.71 m). The box weighs 3 kg instead of 5 kg. Dex1-1 has no palm, so the box is carried by squeezing it between the open grippers, and a 5 kg box slips out while walking. BiGym also accepts a box pressed against the side of the counter.
put_cups#
Goal: put the two cups from the counter into the wall cabinet.
Success: both cups touch the bottom shelf of the wall cabinet and are not held. The glass doors start closed and need not be closed again.
Reset: the cups take 2 of 3 spots 0.15 m apart across the counter, each moved ±0.03 m in x and y, with yaw 180° ± 30°.
vs. BiGym: lowered wall cabinet.
saucepan_to_hob#
Goal: take the saucepan out of the closed cabinet and put it on the hob.
Success: the saucepan touches the hob and is not held.
Reset: the saucepan moves ±0.05 m in x and y on the shelf, with yaw 90° ± 20°.
vs. BiGym: the saucepan starts 0.08 m further forward, at the front of the shelf. At the BiGym position the handle is at the end of a straight arm for a squatting G1.
sandwich_remove#
Goal: use the spatula to move the sandwich from the frying pan onto the chopping board.
Success: the sandwich lies flat within 10°, either face up, and touches the board. Fail-fast: a gripper touches the sandwich, so the spatula is required.
Reset: the pan sits on the hob, moved ±0.02 m, with yaw ±15°. The spatula keeps a fixed offset from the pan. The sandwich lies on the pan, moved ±0.01 m, with random yaw. The board has yaw ±5°.
vs. BiGym: the robot spawns 0.25 m to the left, so the left shoulder faces the pan handle and the right shoulder faces the spatula. It walks the last 0.25 m to the counter. The pan yaw varies by ±15° instead of ±30°, which keeps the handle within reach on every seed.
wall_cupboard_open#
Goal: open both doors of the wall cabinet.
Success: both doors are within 9° of fully open.
Reset: none. The doors start closed on every seed.
vs. BiGym: lowered wall cabinet.
wall_cupboard_close#
Goal: close both doors of the wall cabinet.
Success: both doors are within 9° of closed.
Reset: none. The doors start fully open on every seed.
vs. BiGym: lowered wall cabinet. The doors open toward the robot, and their edges are 0.64 m ahead of the settled pelvis, one step away.
Tasks released later#
These tasks can be built with make but are not part of the benchmark. They
have no published demonstrations yet, and their budgets are placeholders taken
from BiGym. All of them use the 21-dim action.
Task |
Goal |
|---|---|
|
Open all three drawers. |
|
Close all three drawers. They start open. |
|
Open every drawer and door of the kitchen set. |
|
Close every drawer and door. They start open. |
|
Open the door and pull out both trays. |
|
Pull out both trays. The door starts open. |
|
Push both trays back. The door starts open. |
|
Move two cups from the upper tray to the counter. |
|
Put a cup in the closed wall cabinet, then close the dishwasher and the cabinet. |
|
Move the knife and fork from the basket to a tray on the counter. |
|
Put the fork in the tray inside a closed drawer, then close the dishwasher and the drawer. |
|
Move two plates from the lower tray to the drainer. |
|
Put a plate in the rack inside the closed wall cabinet, then close the dishwasher and the cabinet. |
|
Take two cups out of the closed wall cabinet and put them on the counter. |
|
Move the box from the counter to the shelf in the cabinet below. |
|
Move the saucepan and the pan from the hob to the cabinet below. |
|
Use the spatula to put the sandwich in the frying pan. |
|
Flip the sandwich in the frying pan with the spatula. |
|
Put a random set of groceries in the cabinets below the counter. |
|
Put a random set of groceries in the wall cabinet and on the open shelf. |